
Open-source biped · LibreZoo开源双足机器人 · LibreZoo 狸波
A 725-gram duck that learned to walk in simulation. 一只 725 克的小鸭,在仿真里学会了走路。
Fourteen joints, one camera eye, one neural policy at 50 Hz. Pull it apart below, then run the real policy in your browser tab — no install, no server. 14 个关节,一只相机眼,一个 50 Hz 的神经网络策略。往下拉开它,再在浏览器里运行真实的策略——无需安装,无需服务器。
- joints关节
- 14
- grams克
- 725
- Hz policyHz 策略
- 50
- servers服务器
- 0
Take it apart.把它拆开。
32 printed parts, 14 servos, a compute board, a battery and a camera. Scroll to pull the whole robot open. 32 个打印件、14 个舵机、一块计算板、一块电池和一颗相机。向下滚动,把整只机器人拉开。
- 01Head domePrinted shell over the camera and compute board.头壳包住相机与计算板的打印外壳。
- 02Eye ringOne camera, one expression: it swells when Duck quacks.眼圈一只相机、一种表情:嘎嘎叫时它会鼓起来。
- 03Body shellTwo halves around the battery and power board.躯干壳左右两半,包住电池与电源板。
- 04Hip coverCloses the hip-roll joint. Mirrored left and right.髋盖封住髋横滚关节,左右镜像。
- 05ShinLinks the knee servo to the ankle.小腿连接膝部舵机与踝关节。
- 06Sole padSoft print under each foot. The only part that touches the floor.足垫每只脚下的软质打印件,唯一接触地面的零件。
Runs in a tab.在一个标签页里运行。
MuJoCo physics compiled to WebAssembly. The same ONNX policies the robot runs, evaluated at 50 Hz on your CPU. Walk it, sprint it, swap its feet for rollers, or drop in a song and watch it dance. MuJoCo 物理引擎编译为 WebAssembly,机器人实机使用的同一批 ONNX 策略,在你的 CPU 上以 50 Hz 推理。让它走、冲刺、把脚换成轮子,或者丢进一首歌,看它跳舞。
- WASDwalk, Shift to sprint行走,Shift 冲刺
- Mfeet ⇄ rollers双足 ⇄ 轮足
- Dance Labyour audio, analysed locally你的音频,仅在本地分析
- Gamepadplug one in and go插上手柄即可
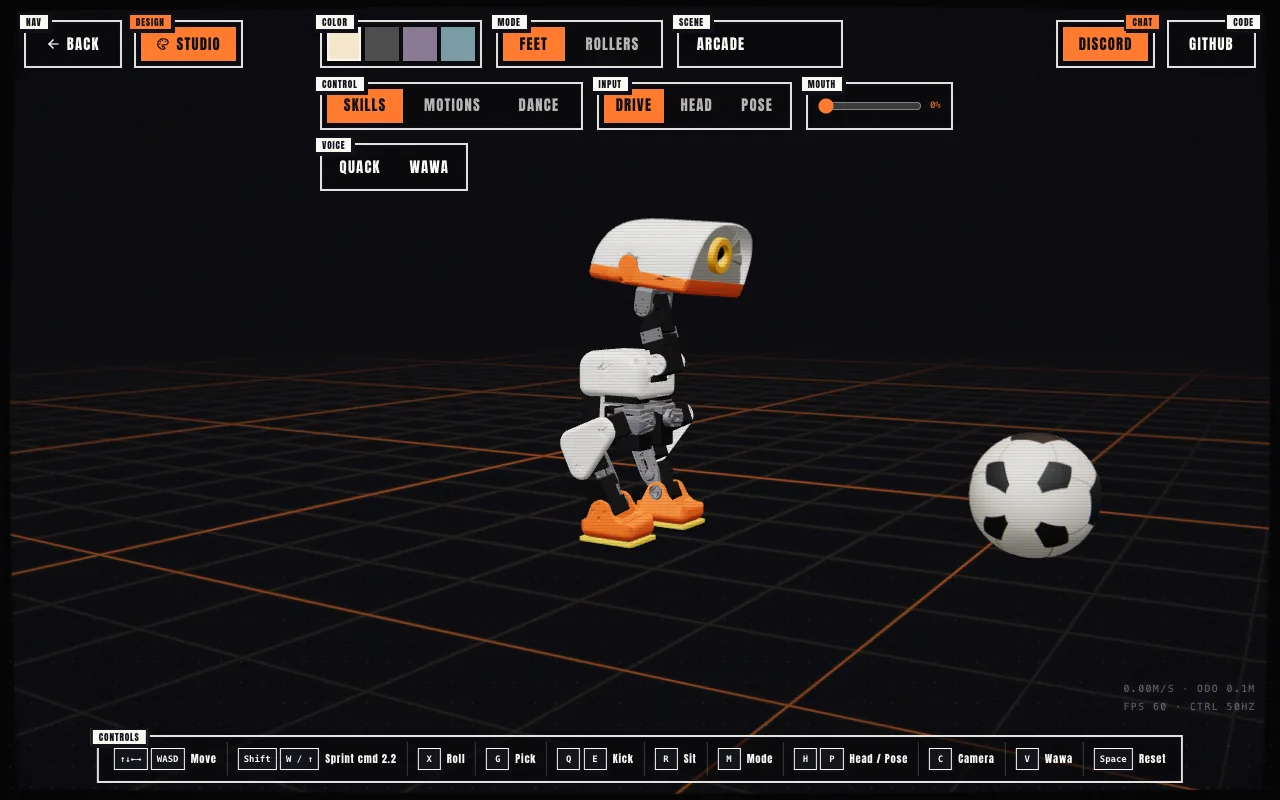 live · 50 Hz实时 · 50 Hz
Make it yours.让它成为你的。
Pick a colourway — Duck repaints live. Colour Studio goes further: every printed part gets its own colour and exports as numbered 3MF files grouped by Bambu filament, ready to slice. 选一套配色,小鸭实时换装。Color Studio 更进一步:每个打印件单独上色,并按 Bambu 耗材颜色分组导出带编号的 3MF 文件,可直接切片。
Built in the open.在开源中构建。
Training environments, actuator models, the controller and this simulator are public. Read them, fork them, send a patch. 训练环境、舵机模型、控制器和这个模拟器都是公开的。阅读、Fork、提交补丁。
- microduckThe robot: runtime, drivers and deployment.机器人本体:运行时、驱动与部署。Rust · Apache-2.0
- microduck_rlReinforcement-learning environments built on mjlab.基于 mjlab 的强化学习训练环境。Python · Apache-2.0
- bamIdentify and simulate servo friction models.辨识并仿真舵机摩擦模型。Python · Apache-2.0
- wbc-mjlabOne policy, any motion: whole-body tracking.一个策略,任意动作:全身跟踪。Python · Apache-2.0
- microduck-simulatorThis simulator, Colour Studio and the iOS app.本模拟器、Color Studio 与 iOS 应用。JavaScript
- Join LibreZoo加入 LibreZoo 狸波All repositories on GitHub.GitHub 上的全部仓库。github.com/micro-zoo ↗